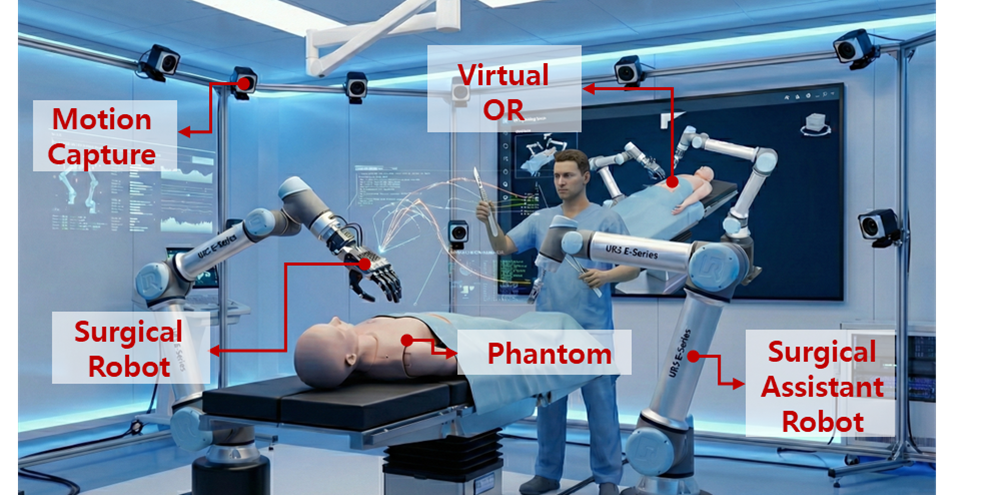
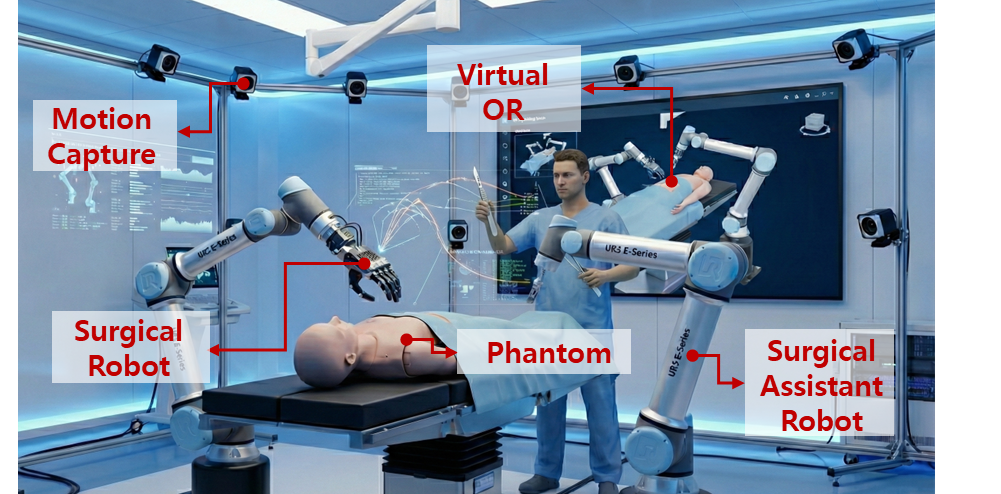
Surgical Robot & Virtual OR is an integrated Physical Twin–Virtual OR platform that supports repeatable preclinical experiments for both surgical robot verification and data-driven surgical AI development. We build standardized task scenarios and quantitative safety/performance metrics, instrument the testbed to capture synchronized multimodal signals (e.g., motion/pose, force–torque, vibration, tool–tissue interaction states), and stream these logs into a Virtual OR for replayable evaluation and digital alignment. This closed-loop workflow accelerates iterative design–test–improve cycles while producing high-quality datasets to train, validate, and benchmark surgical AI under controlled yet clinically relevant conditions.