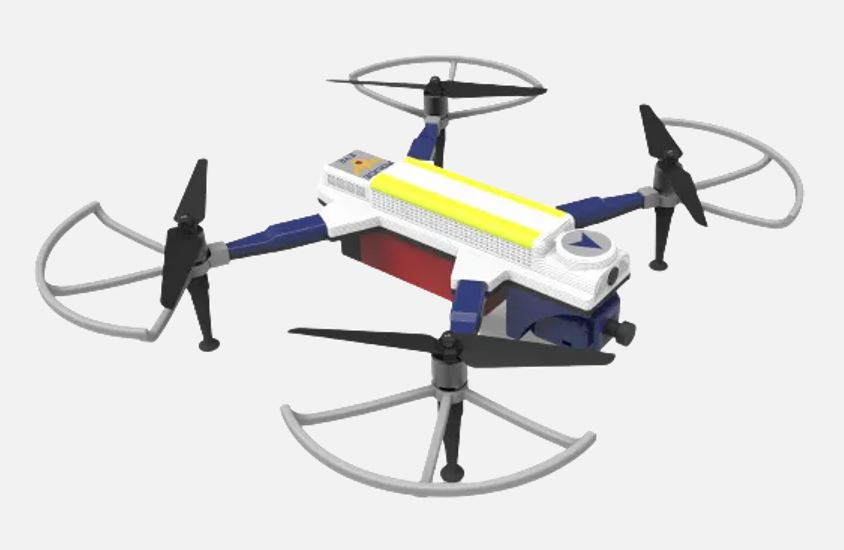
A Multirotor UAV operates based on a unique structure compared to traditional fixed-wing or single-rotor systems. It uses multiple rotors, typically arranged symmetrically, to generate lift with electric propulsion units. Each rotor can be individually controlled to adjust thrust, enabling the UAV to hover, move in any direction, or perform agile maneuvers. This multi-rotor configuration eliminates the need for complex mechanical linkages or control surfaces, offering a simpler yet highly versatile design. Such characteristics make multirotor UAVs suitable for applications ranging from precision inspections to autonomous urban air mobility. The following sections will explore the design and advancements shaping the future of UAV technology.